OpenDubsBest example
Running both arms at once
- Code I wrote
- 487 lines
- Language
- Python
- Tools
- ROS 2, MuJoCo
- Hardware
- 2× OpenArm
- Role
- Solo
- Status
- On the robot
Also shows: PythonROS 2Motion planning
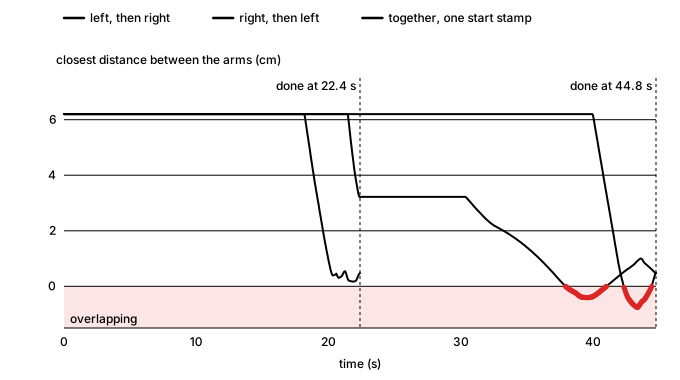
A two-arm plan is only safe if both arms run it together: it was checked with each arm where the other would be at the same instant. On hardware, though, mj_manipulator_ros, the lab's layer that runs those plans on the robot, ran multi-arm plans one arm after the other, which doubled the time and passed through states the planner never checked. Replaying the crossing plan that way in MuJoCo and checking every fourth of its states, the arms intersect in 97 of 1,400.
I rebuilt execution so every arm starts its trajectory on one shared start stamp: the trajectories must share their timestamps, one stamp a moment in the future is computed once, and each arm sends its goal from its own thread against that stamp, so the motors start together however long each goal takes to send. If any arm fails or is aborted, a shared event cancels the others mid-motion. Running two arms from two threads also meant making the shared code thread-safe: both threads stepped one MuJoCo model, and concurrent runs crashed until I serialized every access to it behind one lock. To bring it all up on the real robot safely, I built a hardware-in-the-loop bring-up protocol.