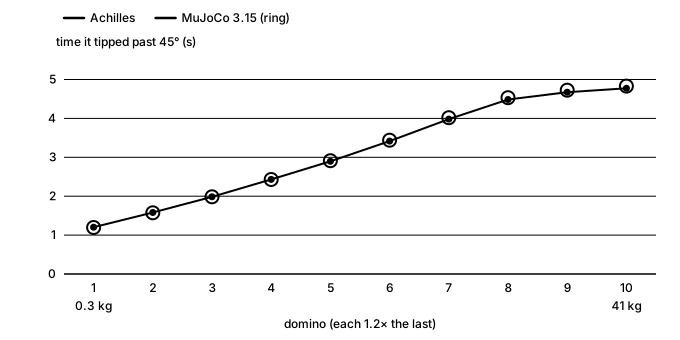
AchillesBest example
Collision response
- Code I wrote
- 2,041 lines
- Language
- C++20
- Tools
- MuJoCo
- Hardware
- Laptop
- Role
- Solo
- Status
- On a branch
Also shows: Kinematics & DynamicsC++
Detecting contacts is only half the battle; working out what happens next is the rest. Once accelerations and contacts are known, the solver adjusts the accelerations so bodies respect their contacts. It uses a "soft contact" model in which each contact acts like a stiff spring-damper, pushing harder the deeper and faster two bodies collide. Friction follows Coulomb's law, whose cone of allowed forces is approximated by a four-sided pyramid of push-only edges, letting bodies grip or slide. Each frame, the solver minimizes
½ (a − a₀)ᵀ M (a − a₀) + Σᵢ ½ Dᵢ (Jᵢ a − a_ref,ᵢ)²,
staying close to the unconstrained acceleration a₀ while penalizing contact violations. It warm-starts from the previous frame's solution when that costs less, then runs a fixed 20 conjugate-gradient iterations to suit SIMD and GPUs, never building the mass matrix. The corrected acceleration then goes to the integrator.