OpenDubsBest example
Bring-up: the Thor, Docker and the drive code
- Code I wrote
- 275 lines
- Language
- Python
- Tools
- ROS 2, Docker
- Hardware
- Jetson Thor
- Role
- Team
- Status
- On the robot
Also shows: ROS 2
OpenDubs runs on an NVIDIA Jetson Thor, so the first job was getting it ready for the whole team. I flashed JetPack onto it, got its IO talking to the rest of the robot, and set up the Docker environment we all develop in: a ROS 2 image with the build tools, Makefile and VS Code tasks to build and debug inside it, and per-person git identities so four people can commit from one shared machine.
The first version of the base drove its four mecanum wheels through a Pixhawk running ArduPilot, over MAVROS; it has since dropped the Pixhawk. With another intern, I brought up that drive code, then added what the rest of the stack needed: a URDF and an SDF with collision geometry for RViz and Gazebo, and a service that records topics to rosbags. Every test after this was a bag I could replay.
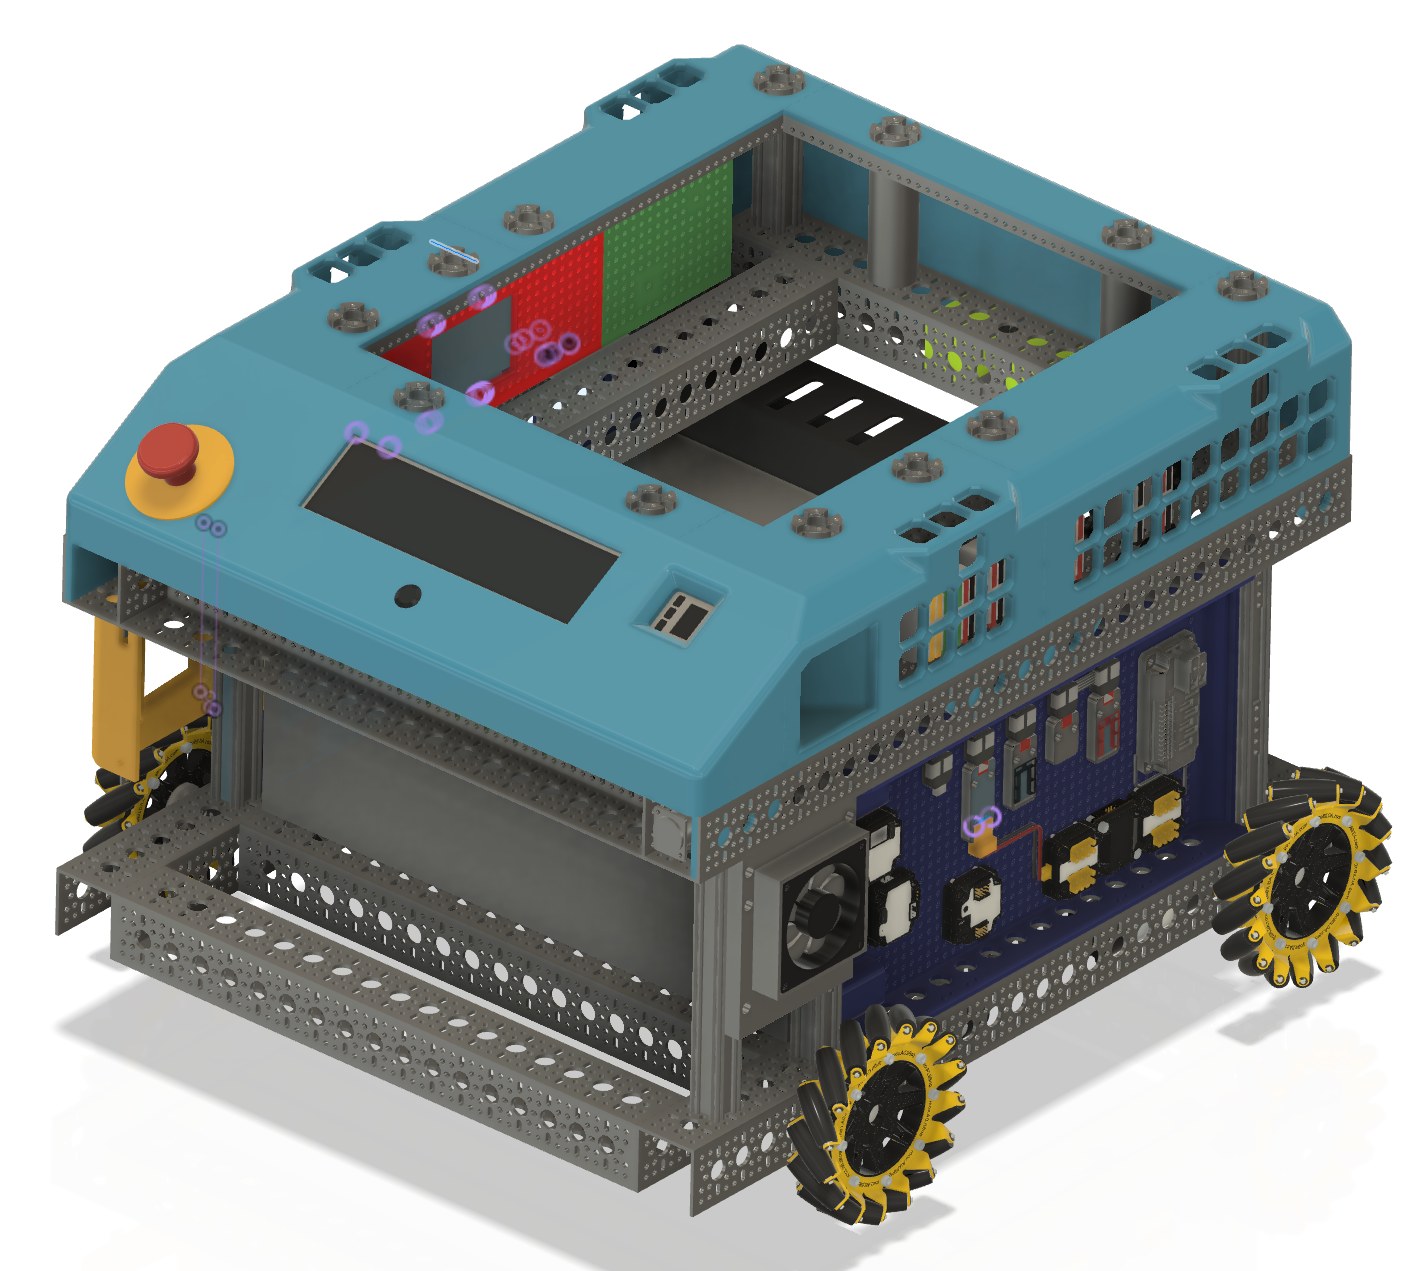
The base has since been rebuilt by others in the lab (I didn't work on it), without the Pixhawk, and carries everything else: a 51.2 V LiFePO4 battery, an emergency stop on the deck and a status display, all wired into one aluminum frame, with the arms, the Thor and the lidars riding on top.