OpenDubsBest example
Two 2D lidars, merged into one scan
- Language
- Python
- Tools
- slam_toolbox, Nav2
- Hardware
- 2× RPLIDAR A1
- Role
- Team
- Status
- In simulation
Also shows: State estimationROS 2Hardware bring-upPython
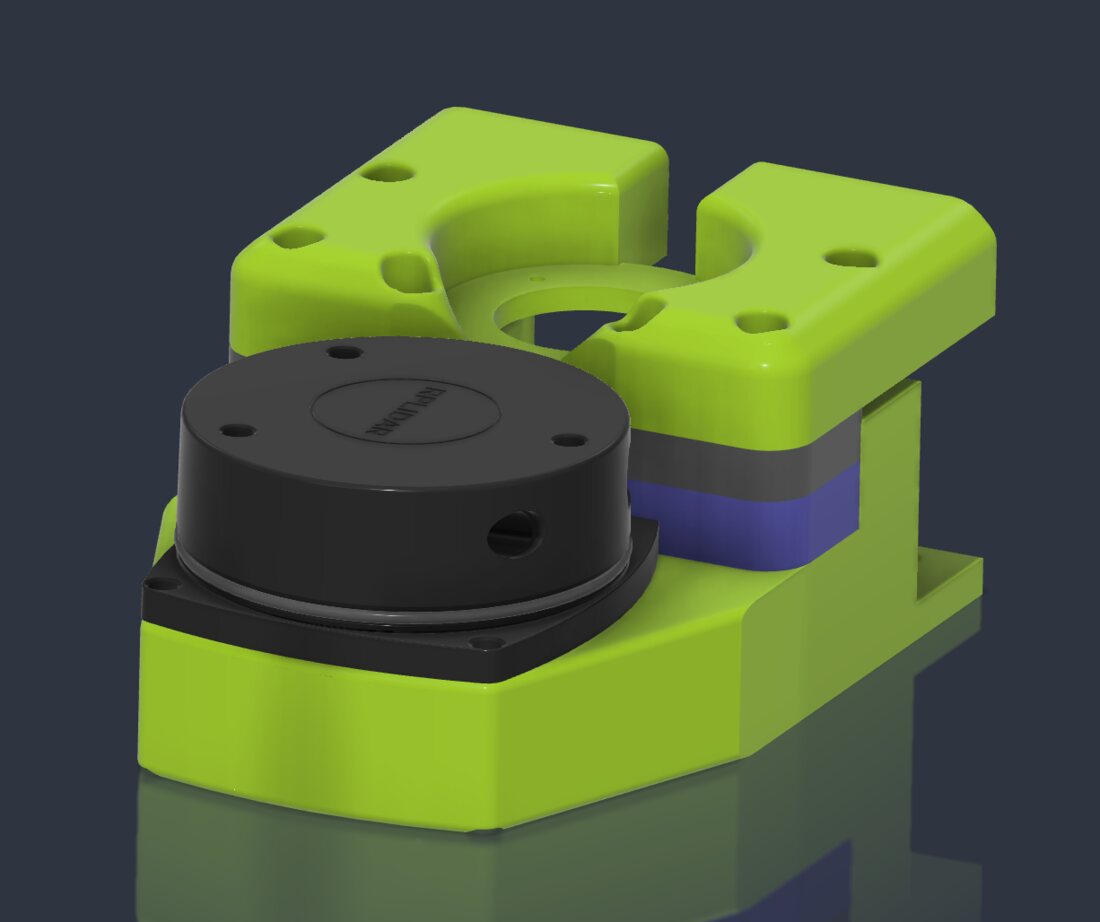
For localization and a map, the base carries two RPLIDAR A1 2D lidars, one at the front and one at the back. Bringing them up, with the team, was mostly fighting USB: the two units have identical USB IDs, so udev rules name each by the hub port it's plugged into, and they power up a few seconds apart so neither times out.
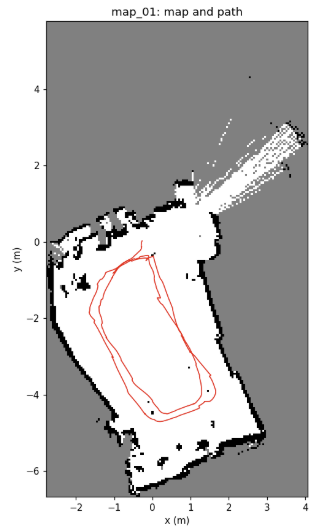
Mapping and Nav2 expect one scan, so I wrote a node that merges the two. The two scans never line up on their own: nothing guarantees the lidars spin at exactly the same rate or finish a revolution at the same moment, and each reaches the Thor with its own latency. So the node pairs scans by their timestamps (any two within 0.1 s), looks up each scan's transform into the robot's frame at that scan's own timestamp, resamples both to the finer of the two angular resolutions, and keeps the nearest return in each direction of one 360° scan, stamped halfway between the two and dropping hits on the robot itself. On top of it, I set up slam_toolbox and Nav2, which drove the robot point to point in simulation.