← All skills

Skill

SLAM

Simultaneous localization and mapping: building a map while locating the robot in it. slam_toolbox on OpenDubs's merged lidar scan, and the Odin's relocalization into a prebuilt map on ARUW's sentry.

3 log entries2 projects

OpenDubsBest example

Two 2D lidars, merged into one scan

Also shows: State estimationROS 2Hardware bring-upPython

For localization and a map, the base carries two RPLIDAR A1 2D lidars, one at the front and one at the back. Bringing them up, with the team, was mostly fighting USB: the two units have identical USB IDs, so udev rules name each by the hub port it's plugged into, and they power up a few seconds apart so neither times out.

Mapping and Nav2 expect one scan, so I wrote a node that merges the two. The two scans never line up on their own: nothing guarantees the lidars spin at exactly the same rate or finish a revolution at the same moment, and each reaches the Thor with its own latency. So the node pairs scans by their timestamps (any two within 0.1 s), looks up each scan's transform into the robot's frame at that scan's own timestamp, resamples both to the finer of the two angular resolutions, and keeps the nearest return in each direction of one 360° scan, stamped halfway between the two and dropping hits on the robot itself. On top of it, I set up slam_toolbox and Nav2, which drove the robot point to point in simulation.
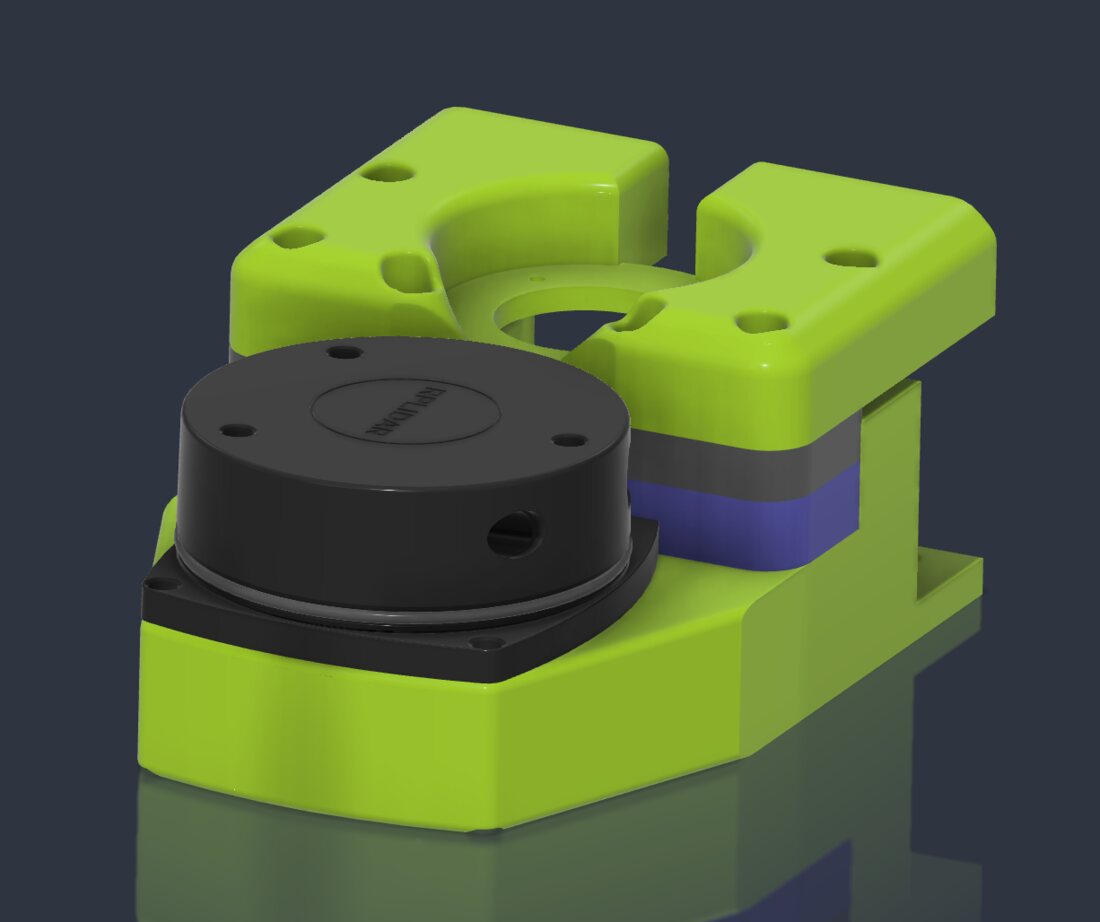
A CAD render of a round 2D lidar sitting in a bright green 3D-printed mount
One of the two lidar mounts. CAD render from the lab's build guide.
A replay in Gazebo: the robot's URDF, my lidar merger and our slam_toolbox settings, unmodified, mapping a made-up lab room while Nav2 drives. 6× speed.

Advanced Robotics at UW

A test platform against motion capture

Code

Also shows: Experiment designPython

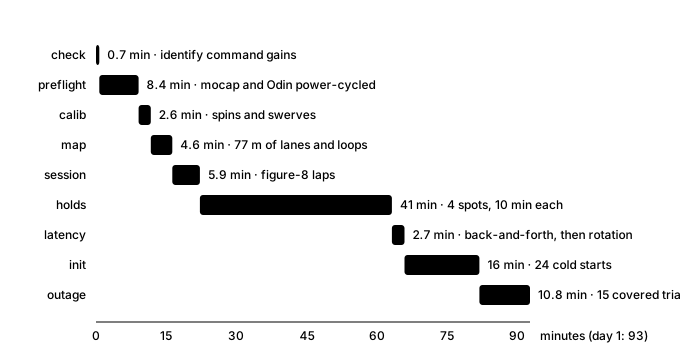
The sentry localizes with an Odin1, a lidar-inertial sensor that relocalizes into a prebuilt map. Before the team decided whether the whole localization system could rely on it alone, we wanted to know how accurate it is and where it is weak. So I built a test platform that measures it against the motion capture room, whose OptiTrack tracks the robot to a fraction of a millimeter. It starts and stops the sensor, records every run, guides whoever is driving with live mocap feedback, and can also drive the robot itself through the Jetson and the robot's controller, with a watchdog and speed caps. A campaign day runs a fixed protocol: calibration spins, a mapping drive, figure-8 laps at set speeds, ten-minute holds, back-and-forth motion to measure latency, cold starts, and outages where someone covers the sensor.

Diagram of the system: motion capture and the Odin1 sensor feed the characterization scripts, which record every run and write a report; in autonomous mode they send chassis velocities over UDP to the Jetson, which forwards them over UART to the sentry's motor control board
The three parts, and the default human-driven mode.
Bar timeline of day 1: preflight 8 minutes, calibration 3, mapping 5, figure-8 laps 6, holds 41, latency 3, cold starts 16, outages 11; 93 minutes in all
Day 1, step by step, from the campaign's time estimate.

Advanced Robotics at UW

An error model for the Odin

Analysis code

Also shows: State estimationExperiment designPython

The question wasn't how accurate the Odin is but whether the sentry could rely on it alone, and one accuracy number can't answer that: the nav stack needs to know how the error behaves, whether it grows, and what happens when something goes wrong. So I designed the October 3 campaign around those questions (figure-8 laps, a long hold, repeated relocalizations and covered-sensor trials, all against mocap) and fit a small model to it: the true pose, plus an offset drawn each time the Odin relocalizes into its map, plus first-order Gauss-Markov noise: correlated over time, but decaying.

poseout(t)=posetrue(t−τd)⊕ε(t),τd≈0
ε(t)=R(ψ)Tbk+η(t)
bk∼N(0, diag(σb2)),per relocalizationk
ηi[n+1]=aiηi[n]+σi1−ai2wi[n]
ai=e−Δt/τc,i,Δt=0.1s

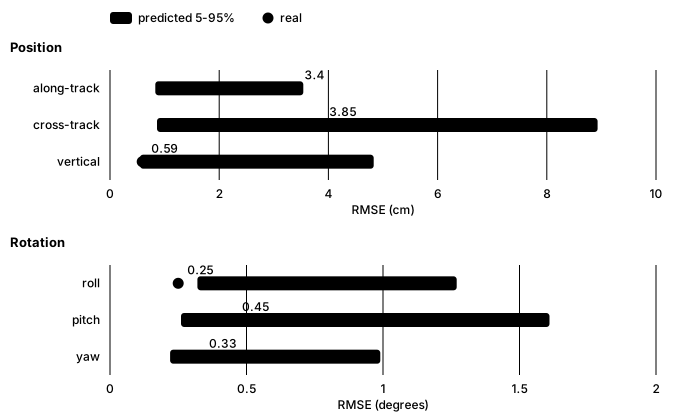
Splitting the error this way was the key decision. The offset from each relocalization turned out to be the largest term, which one overall noise figure would have blurred, and modelling the noise as decaying showed the error stays bounded instead of drifting. To check the model wasn't just describing the data it was fit to, I refit it without one session, simulated it many times along that session's real path (a Monte Carlo check), and asked whether the real error fell where the simulations said it would. It did: its real error there, 5.1 cm horizontal and under half a degree, matched the prediction on all six axes (roll came in just under its predicted range, still within the test). That made the recommendation clear: the Odin can be the sentry's only localization, kept on the turret major, where it swivels independently of the turret and the chassis. We tried it in several mount locations and found the occlusions made little difference. The nav stack only has to handle a rare wrong relocalization, and the output pausing while the sensor is covered.

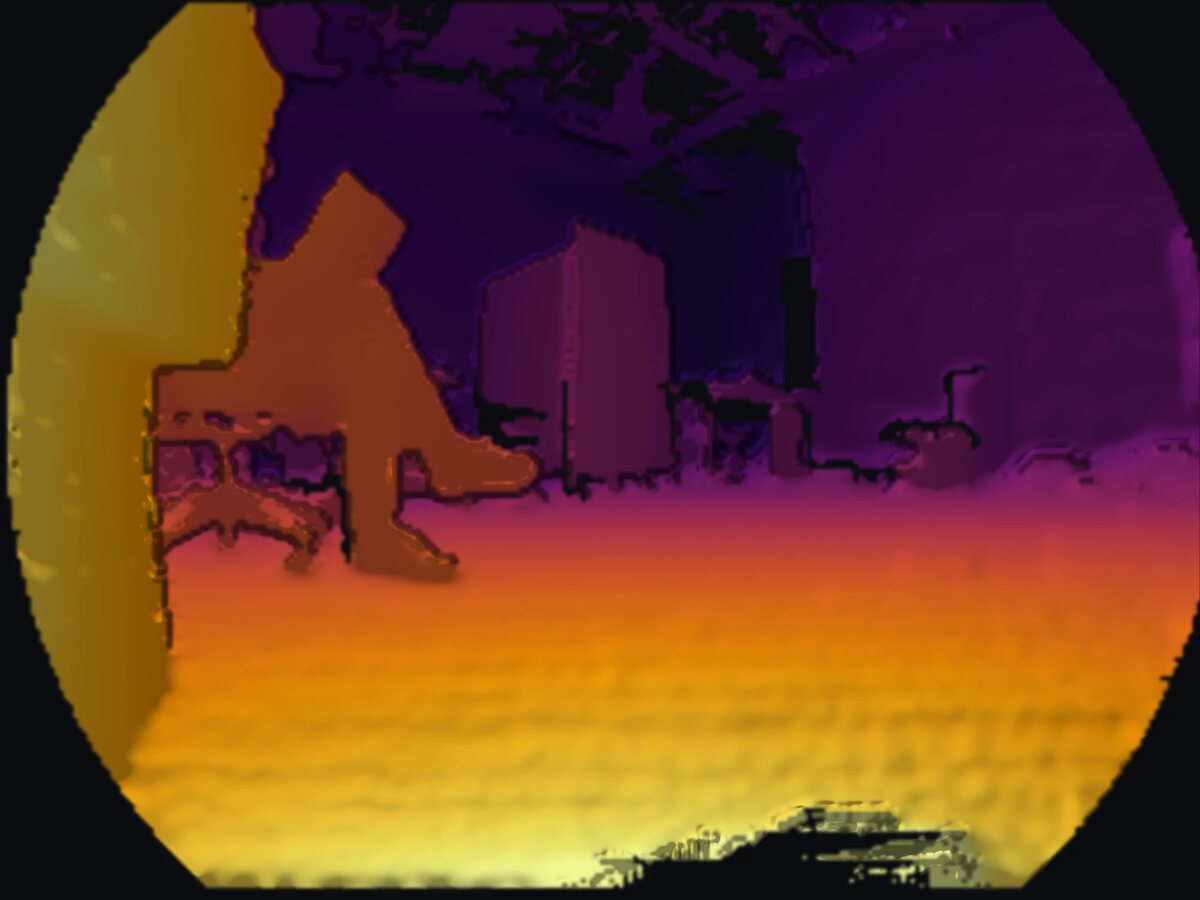
Depth image from the Odin, colored from yellow for near to purple for far, in its round fisheye frame: a wall close by on the left, a person sitting in a chair, and boxes and furniture across the room
What the Odin sees: a depth image from its recordings, near in yellow and far in purple.
Chart: for each axis, the Odin's real error on a held-out session as a dot against the model's predicted range as a bar; along-track, cross-track and vertical position, and roll, pitch and yaw
The hold-out check: the model, refitted without one session, predicts that session's error. Every axis passes; roll comes in just under its predicted range.